That said, it's amazingly impressive what they have achieved.
I am curious as to why the robot's front legs are so close together in some clips -- maybe approximating a 3-legged device was somehow algorithmically simpler?
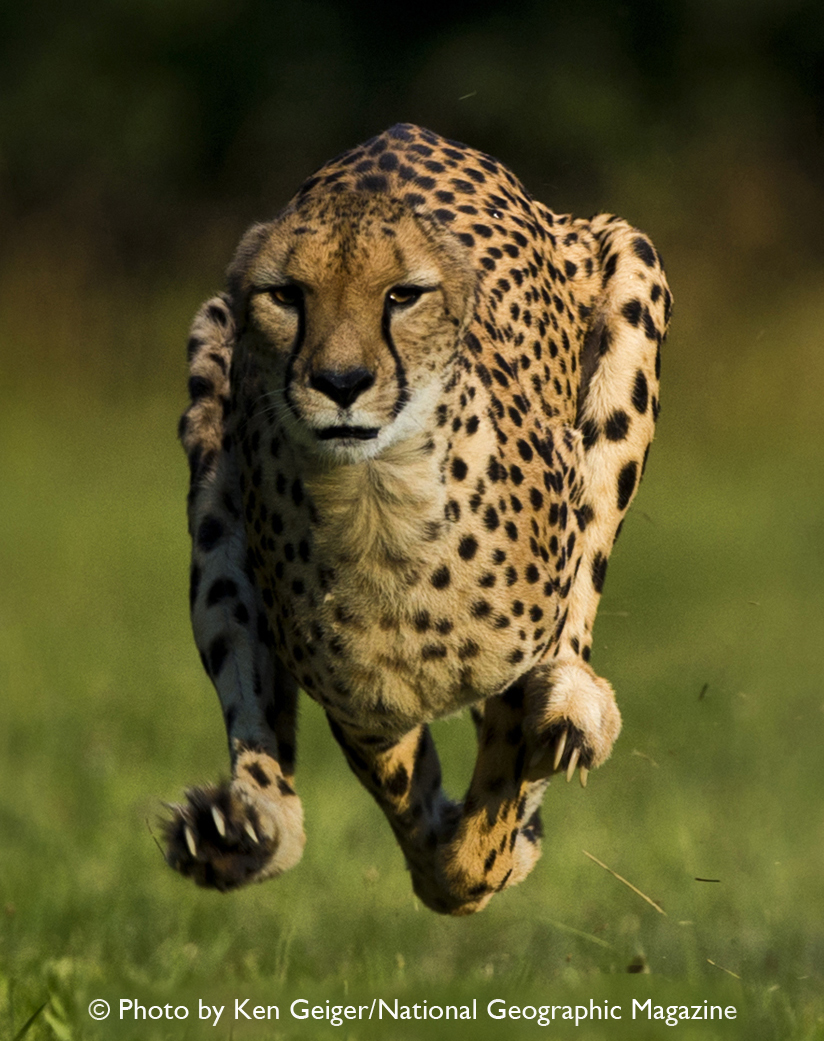
Check out, for instance, this video of an actual cheetah running around: http://www.youtube.com/watch?v=KIeXEiJuJUY - you can see the front paws coming down very close to each other in time and space, followed by the wide-spread rear paws making huge leaps forwards.
Also a quick images search for "horse muybridge" may be enlightening - Muybridge's books are super well-known in the animation circles I come from, as they were the first major works of research into high-speed photography documenting How Stuff Moves. You can see that horses have a whole bunch of different gaits available to them; most other animals are similar, but less tractable to a photographer's whims!
> why the robot's front legs are so close together
I'm thinking there's some kind of efficiency gained, where, to us, it looks precarious and awkward, but to the machine-calculated algorithms, a trend is detected, where it's easier to stay continuously balanced on a small point while in motion, because it can use it's own inertia and apply smaller amounts of torque and pressure to it's actuators, and use smaller movements, when attempting to stay on it's feet.
When it's at rest, a wide stance is probably safest, but in motion, maybe it's a different story. Given that it's a somewhat rigid machine, with appendages that have alimited range of motion, maybe it targets, the smallest most effective movements?
I would also wonder: What is the net energy consumed from it's power source, to cycle one limb, moving it from fully contracted to fully extended and back again? You would need to test this unloaded in free air, and completely loaded under the weight of the entire robot at rest. And that test would not account for the amount of work it would take to safely absorb the full weight ofthe robot, while it's moving at 20MPH, to bring it to a full stop, with a single limb.
I'm not sure if those sorts of efficiencies are anything more than a simple practical concern in a prototype, given that the only goal is to run some quick, untethered tests in a parking lot, but it might be relevant to a small degree.
This is just my amateur guesswork, though.
The way the govt avoids vendor lock-in (in principle anyway) is by farming out the money to multiple vendors, especially as the progress moves towards real practical deployment. They did that with autonomous vehicles, and they're doing it again with legged robotics (http://www.darpa.mil/our_work/tto/programs/darpa_robotics_ch...)
However in this one area (legged locomotion) it seems to me that BD is far, far ahead of anyone else, unless that work is taking place in complete secrecy.
I like the design much better than BD's weighty quadrupeds.
Organizations worldwide, from DARPA, the US Army, Navy and Marine Corps...
I don't understand where you're going here. The linked video shows a robot designed under DARPA's M3 program. This was DARPA's initiative. DARPA has had a string of highly successful practical robotics programs.
Sometimes the government knows what it wants and the programs are very focussed, e.g. we need proof of concept demos for small radios that can perform X, Y, under Z conditions. Sometimes the programs are very blue sky and strategic, e.g. we don't want the other guys to get ahead in robotics, so let's make sure we keep up. Please send us your proposals for around $BALLPARK and we'll pick the most promising.
The focussed kind of program always exists. The funding for blue sky programs comes and goes, depending on the political climate and the personalities of the incumbent director and program managers.
But the government doesn't buy tech to keep it off the streets. One great thing about DARPA funding is that the government doesn't own the IP afterwards. They often don't even insist on a free license to use it themselves. They just want it to exist so they can choose the best stuff later.
It seems like they are getting faster and faster when going from prototype to on the battlefield.
If there is one organization in the entire world that has enough funds to do almost anything it is the US DoD.
Imagine how complex the path planning would have to be for a robot like this to successfully climb and descend a rocky mountain ... not only would it have to plan where to place it's feet for balance, but it would have to look much farther ahead to avoid walking/running into dead-end paths.
0 - http://cs.stanford.edu/groups/littledog/ 1 - http://www.bostondynamics.com/robot_littledog.html
When I saw the big dog prototype not falling when pushed, the assumption I made is that the eventual objective would be to just try to keep going and self-correct when unevenness is encountered.
Never thought about fully automated walkers -- just manually guided, but able self correct on rough terrain.
Product pipelines are tricky, and not everyone has a Steve Jobs to pitch the final release.
http://www.reddit.com/r/apple/comments/1nptvv/susan_bennett_...
http://en.wikipedia.org/wiki/Wright_Flyer
to this:
http://en.wikipedia.org/wiki/Golden_Age_of_Aviation
Give dynamic robots another decade or two, and until that time:
http://www.strandbeest.com/ http://www.youtube.com/watch?v=HSKyHmjyrkA&nofeather=True
(I'm sure that Jansen's aesthetic similarity to the Wright Brothers' flyers is no coincedence)
* Your golden age was about decade out from the Wright flyer and Big Dog has been out for a while.
* More to the point: the airplane had little competition in it's field - the wright flyer was already faster than a balloon. Walking robots' primary advantage is in rough terrain, which is only a advantage in marginal areas (if walkers moved with even the same efficiency as (inherently simpler) wheel vehicles, we would still want to confine them to paved roads. Consider how, relative to a wheel vehicle of the same weight, it's likely a walking robot would take a greater toll than on any path or road it used because it's movement would involve inserting its weights at specific points and pushing).
* Treaded vehicles have around for a while and they do some portion of what a walking vehicle could do in a military setting - an army is quite will to the destroy a forest to move through it. And further, continuous track can things walkers couldn't - moving over swamp and other muck. Walkers might, maybe find a marginal use along side other specialized vehicles. But walkers have an inherent problem - if they are a lot bigger than a horse, what keeps them from sinking in the soft ground they have to be targeted for. If they aren't bigger than a horse, what makes them better than the presumably cheaper horse? http://en.wikipedia.org/wiki/Continuous_track
* We never got our flying cars and video-phones have taken a long time. Shows that not all possible tech becomes practical tech in a simple fashion.
Notice how the indoor version of BigDog has a tether for power and the outdoor has a very loud engine. That noise hardly acceptable on the battlefield.
Are these considered "robots"?
It's interesting to think about the factors that go into this. I could imagine:
* High unit cost
* High maintenance cost, especially in remote locations.
* It is only useful in remote locations where wheeled vehicles can't go.
* It requires special training to operate.
* It doesn't have enough intelligence to avoid obstacles by itself in the remote, rough locations it would otherwise be fit for.
Other ideas?