News for hackers. Stuff that matters.
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by simias on Monday August 06, 2012 @09:44AM (#4345126)
Why don't they just put a camera filming downwards to determine the ground speed? Wouldn't it be simpler and more reliable?
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by ballooney on Monday August 06, 2012 @10:22AM (#4345281)
Light heartedly off topic, but at a decelerators conference last year I had a chance to talk to one of the JPL Entry Descent and Landing peeps, and he mentioned that in Q&As, no single audience utterance carried more foreboding than 'Why don't you just...'

To answer your question more helpfully, having closed loop machine vision stuff is quite computationally intensive, though there is already some on the rover (to help negotiating obstacles or stop if it sees something like a trench (MERs would famously stop at the same time every day, thinking that their now-infront shadow was a pit)) but it's power intensive and expensive (both mass and cost of a dedicated odometry camera, for example) and the lighting conditions are very variable. The MERs developed a technique whereby they would 'shimmy' their steering every so many meters, and then with the rear facing camera snap a photo of their tracks (with shimmies) and infer distance travelled and slippage and so on. This stuff is often easier with humans in the loop as the terrain still throws up unknown unknowns when driving. Here's a pic of the tracks:

http://photojournal.jpl.nasa.gov/jpeg/PIA14129.jpg
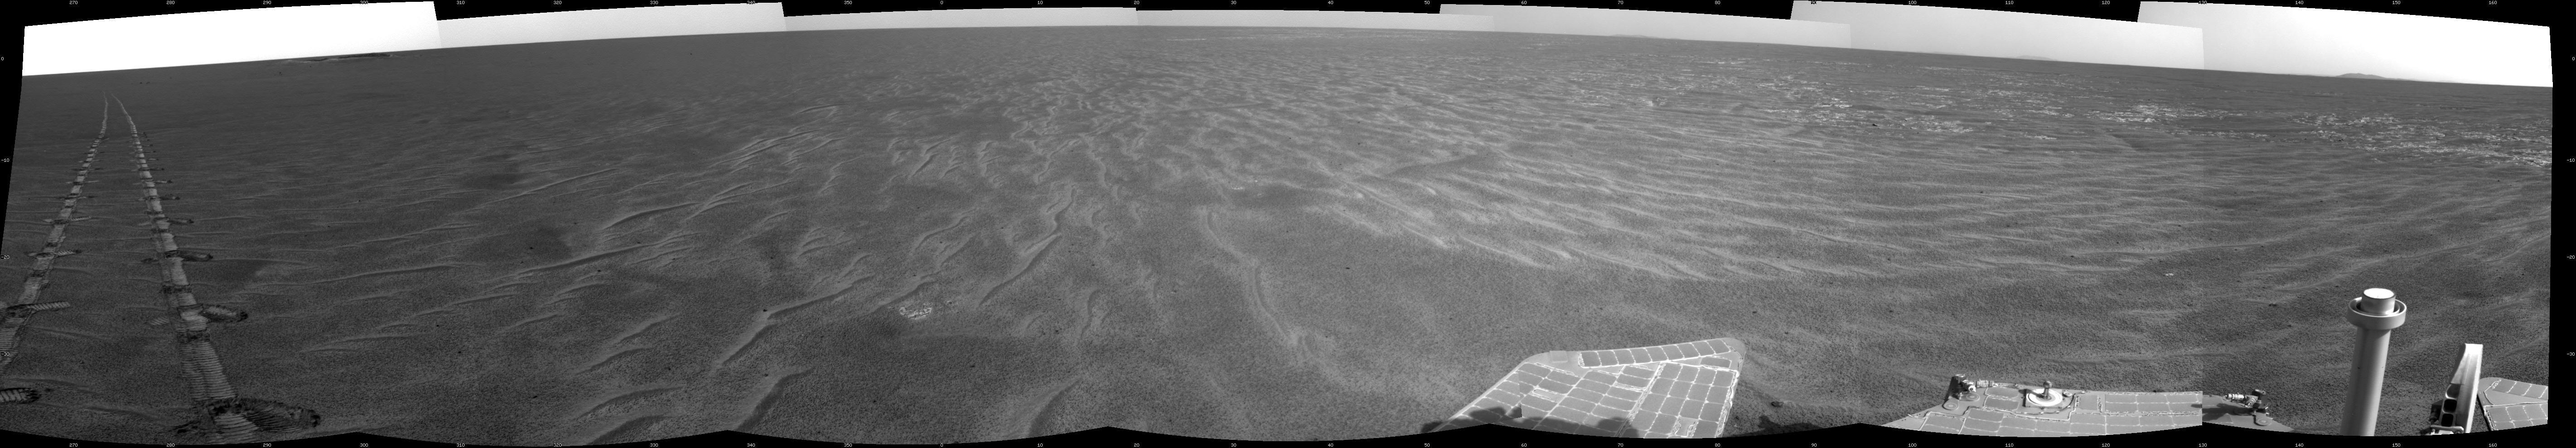
I guess another point is that while it might be a perfectly sensible suggestion technically, there's only so much 'new' they want to risk per mission (the Entry Descent and Landing phase contained a whole lot of 'new' as we know) and they maybe just wanted to carry on doing it in a way they know works ok from before.

Re:Curiosity rover writes Morse Code of JPL everywhere it goes by vasco on Monday August 06, 2012 @10:16AM (#4345260)
As I understood it that's exactly what the camera is doing, and the morse code is just a helpful pattern with a known distance to make more precise measurements of ground speed.

With no patterns one could think of a situation where the surface sand/terrain would be displaced but your actual position was exactly the same.

Re:Curiosity rover writes Morse Code of JPL everywhere it goes by mturmon on Monday August 06, 2012 @04:19PM (#4347060)
All true. JPL has been a world leader in development of visual odometry ("VO"), which is key to estimating slip, which in turn is key to not getting stuck in sand.

The method hinges on establishing correspondence between visual features in before/after images. Then, since you know (through stereo ranging) how far away things are in both images, you can match points and see how far you've gone. This works better the more visual features (tiny edges and corners) you have to cue off of, and presumably these treads are generating more distinguishable features. They ran VO on Spirit and Opportunity, and they will on Curiousity as well.

A summary is in the first page of this little white paper:

http://www.lpi.usra.edu/meetings/marsconcepts2012/pdf/4053.p...

and one full description is here:

http://citeseerx.ist.psu.edu/viewdoc/summary?doi=10.1.1.104....

The good thing is that VO requires no extra hardware, because you already have stereo cameras.

By the way, they do make commercial velocity sensors of the kind described in the GP comment (special camera looking down):

http://www.corrsys-datron.com/optical_sensors.htm

These may not use VO, they might just use optical correlation. Sometimes they're used in robotics.

Re:Curiosity rover writes Morse Code of JPL everywhere it goes by altarelli on Monday August 06, 2012 @04:53PM (#4347214)
Sometimes they're used ...in optical mice. By the millions.
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by frossie on Monday August 06, 2012 @03:51PM (#4346933)
Correct. See 1:15 into the video in the OP that explains the visual odometry system.
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by ck2 on Monday August 06, 2012 @09:56AM (#4345185)
For that matter why not use the same technique a laser/led mouse uses to know how far/fast it's been moved?

They could have one on each wheel and then another set of sensors pointing down, so wheel slippage vs ground movement at that axle.

Re:Curiosity rover writes Morse Code of JPL everywhere it goes by brown9-2 on Monday August 06, 2012 @10:07AM (#4345226)
Wouldn't the ground not being perfectly flat mess with a measurement like that?
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by brudgers on Monday August 06, 2012 @10:19AM (#4345273)
Reasons I can think of include: the ground does not consist of a regular pattern of known length so image processing might be more difficult; looking out over the track allows more data points to be interpreted; an outward looking camera can fulfill more additional roles or be repurposed to compensate for other failed instruments more readily; a downward facing camera is more likely to gather images within the rover's own shadow; other outward facing cameras could use the same algorithm should the distance measuring camera fail.
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by jgrahamc on Monday August 06, 2012 @09:47AM (#4345145)
What happens if the ground moves?
Re:Curiosity rover writes Morse Code of JPL everywhere it goes by simias on Monday August 06, 2012 @09:49AM (#4345154)
In that case certainly the wheel marks will be unexploitable as well? I'm thinking about scenarios such as heavy wind blowing the sand away or sand "avalanches" on slopes.

Besides, a camera would work on hard ground, while this method wouldn't. I don't know if that's a problem in practice on mars of course.